Efficient Event-Based Object Detection: A Hybrid Neural Network with Spatial and Temporal Attention
Contributions
- Hybrid 형태의 SNN-ANN event object detection 모델 제안
- SNN과 ANN 사이를 연결하는 bridge module $\beta_{asab}$ 제안
- ANN 내부에 RNN 구조(DWConvLSTM)를 결합하여, SNN+RNN 구조로 변형, 긴 시간 범위의 temporal 정보를 처리
Method
Process
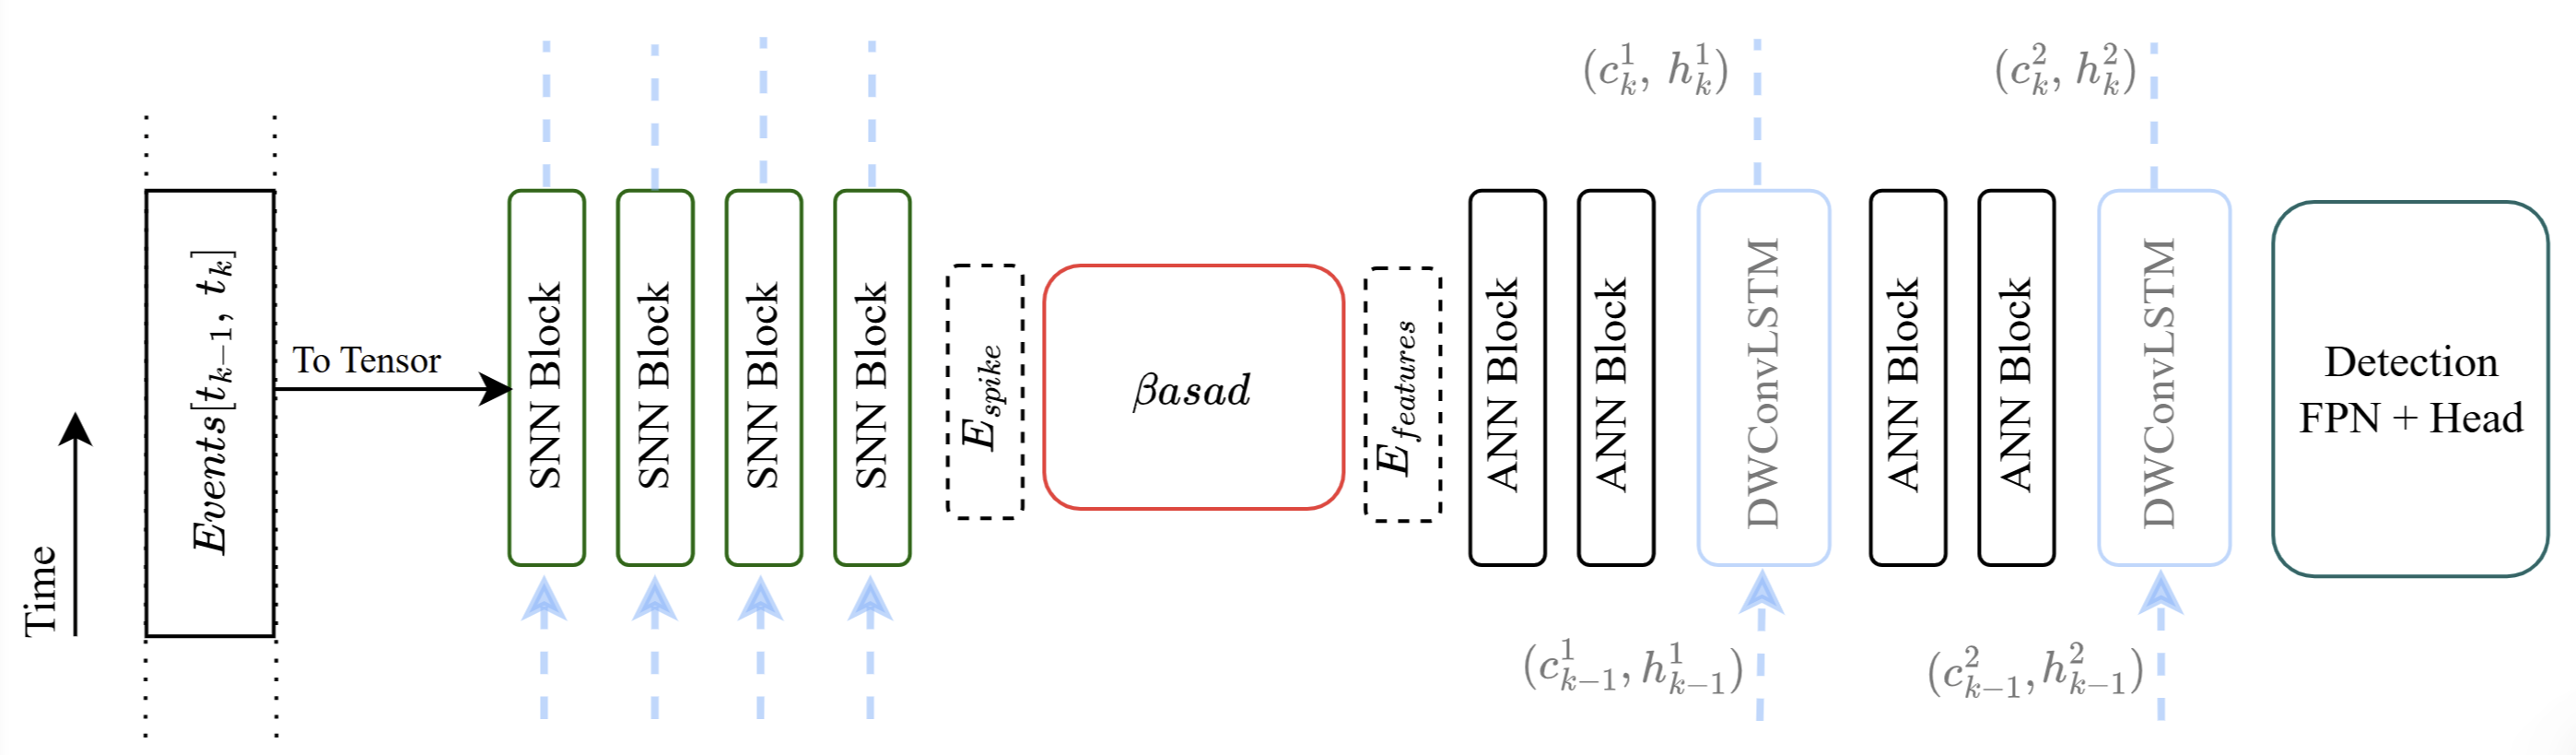
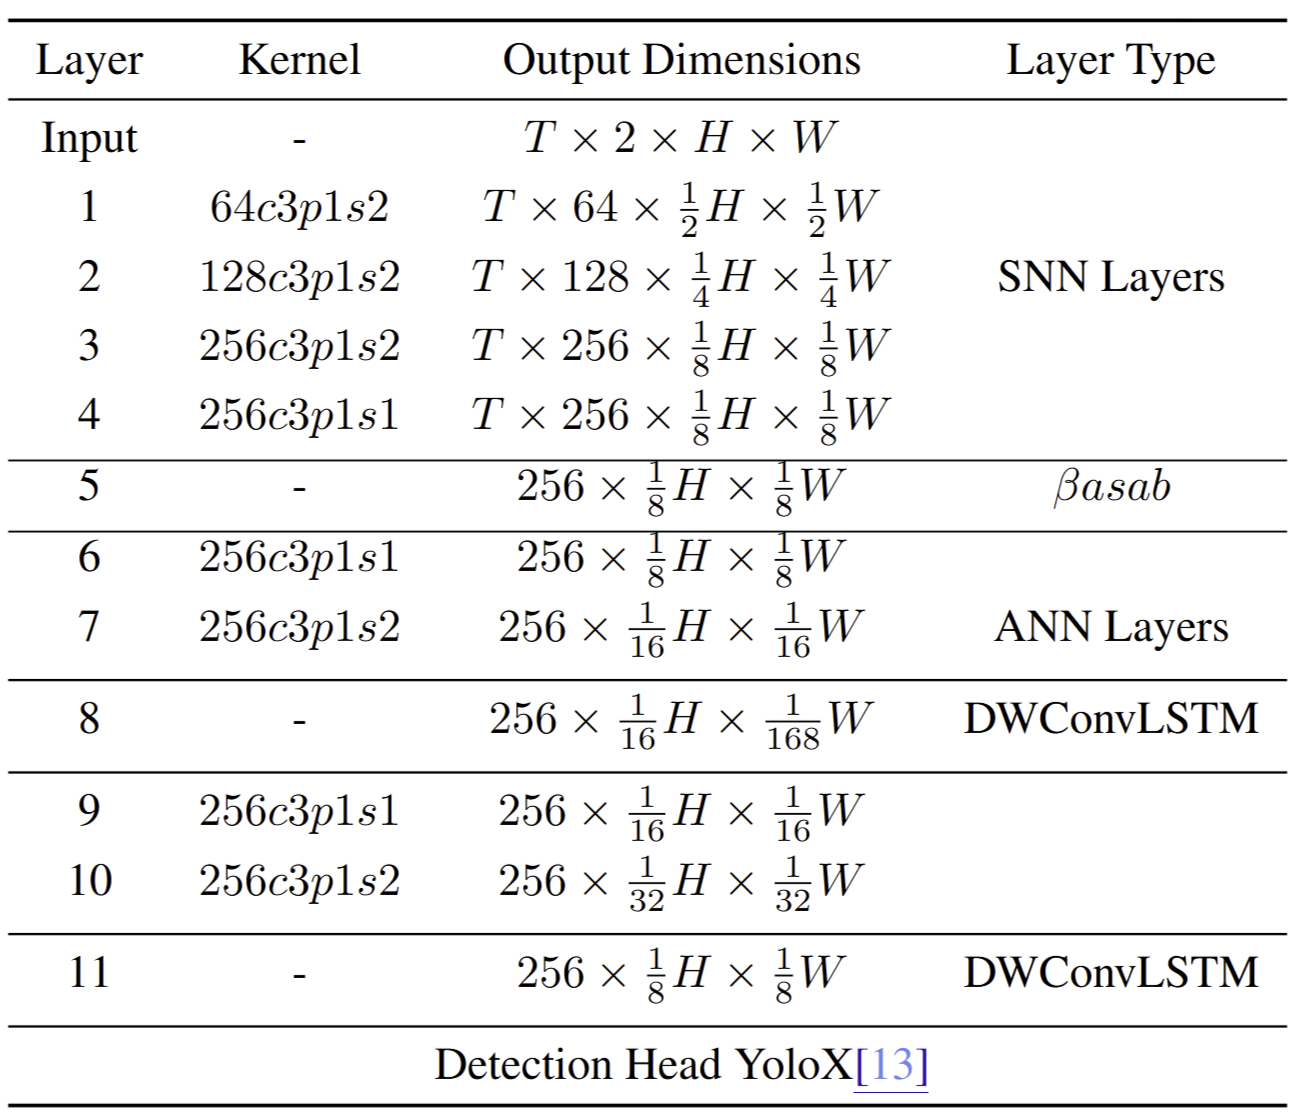
- Event processing
- SNN block : high temporal resolution에서 low-level feature 추출
- Attention-based SNN-ANN Bridge Module → 핵심 모듈
- ANN block & DWConvLSTM : 넓은 시간 구간(slower timescale)에서 dense activation 사용
- Head : 최종 detection
Event processing
- 논문의 모델은 RVT에서 제안했던 event processing을 사용
- Histogram 방식과 voxel grid 방식을 섞어 놓은 것으로 보임
- Event stream 전체 구간에서 세분화된 시간 구간과 polarity를 쪼개서 4차원 tensor로 변환 → $\left[t_{k-1},t_k\right]\in\mathbb{R}^{T\times2\times H\times W}$
- 논문에서는 k와 a,b를 혼용한 듯 함
SNN block
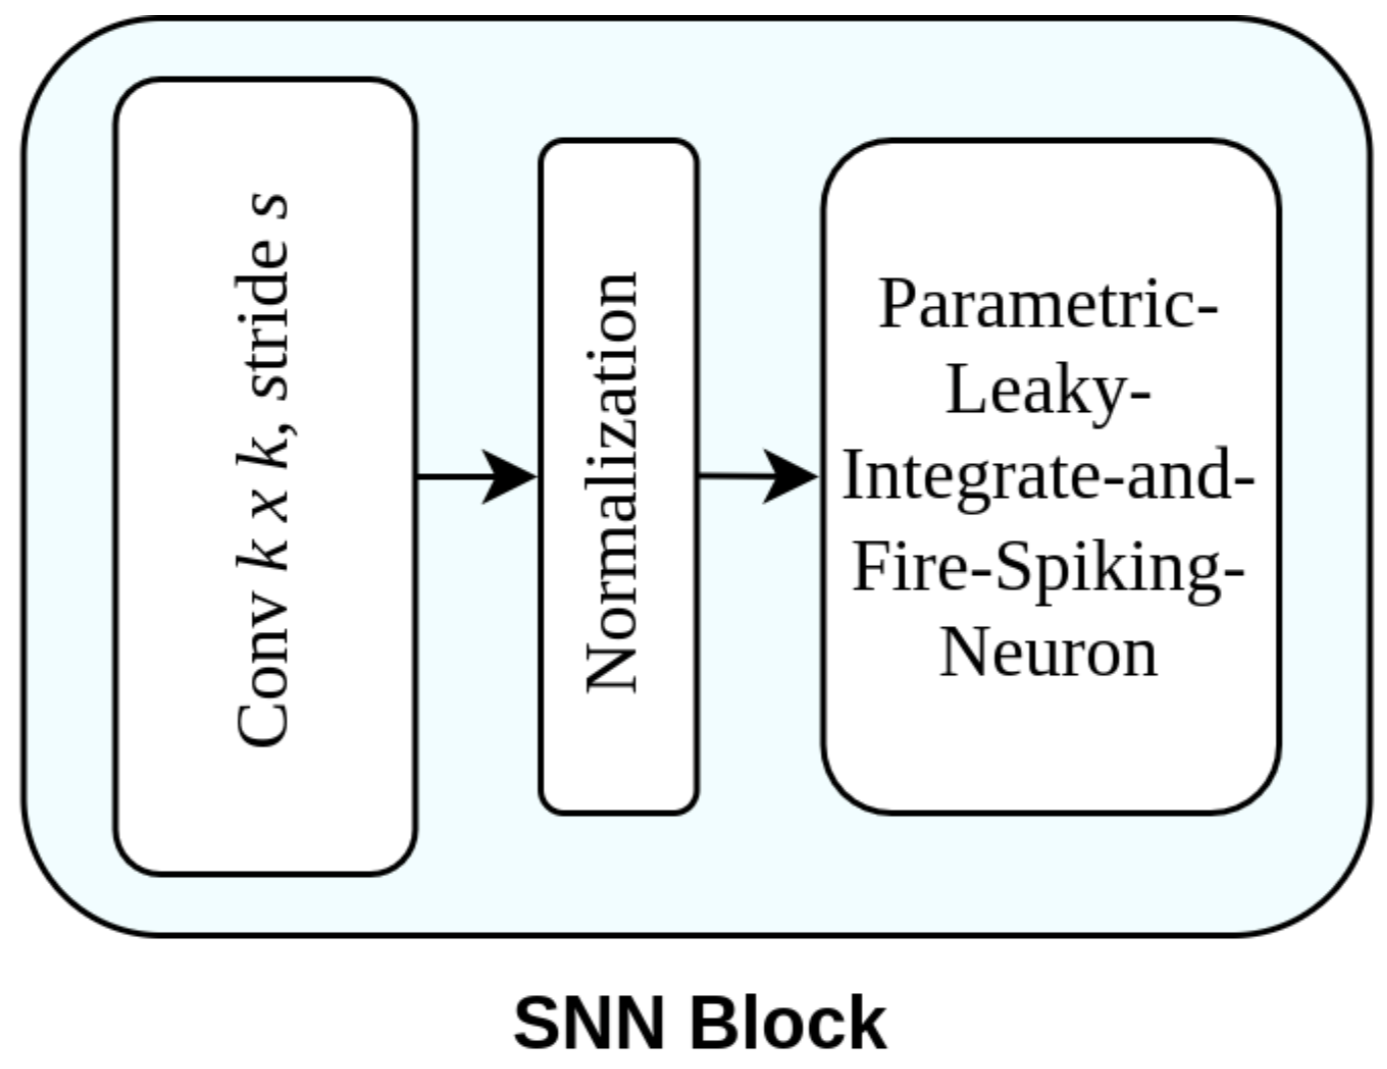
- convolution, batch norm, parametric leaky integration and fire(PLIF)로 구성
$\tau=sigmoid(w)^{-1}$, input이 $X[t]$일 때 막전위:
\[V[t]=V[t-1]+\frac{1}{\tau}\left(x[t]-(V[t-1]-V_{reset})\right)\]- 출력 : $\textbf{E}_{spike}\in\mathbb{R}^{T\times C\times H’\times W’}$
Attention-based SNN-ANN Bridge Module
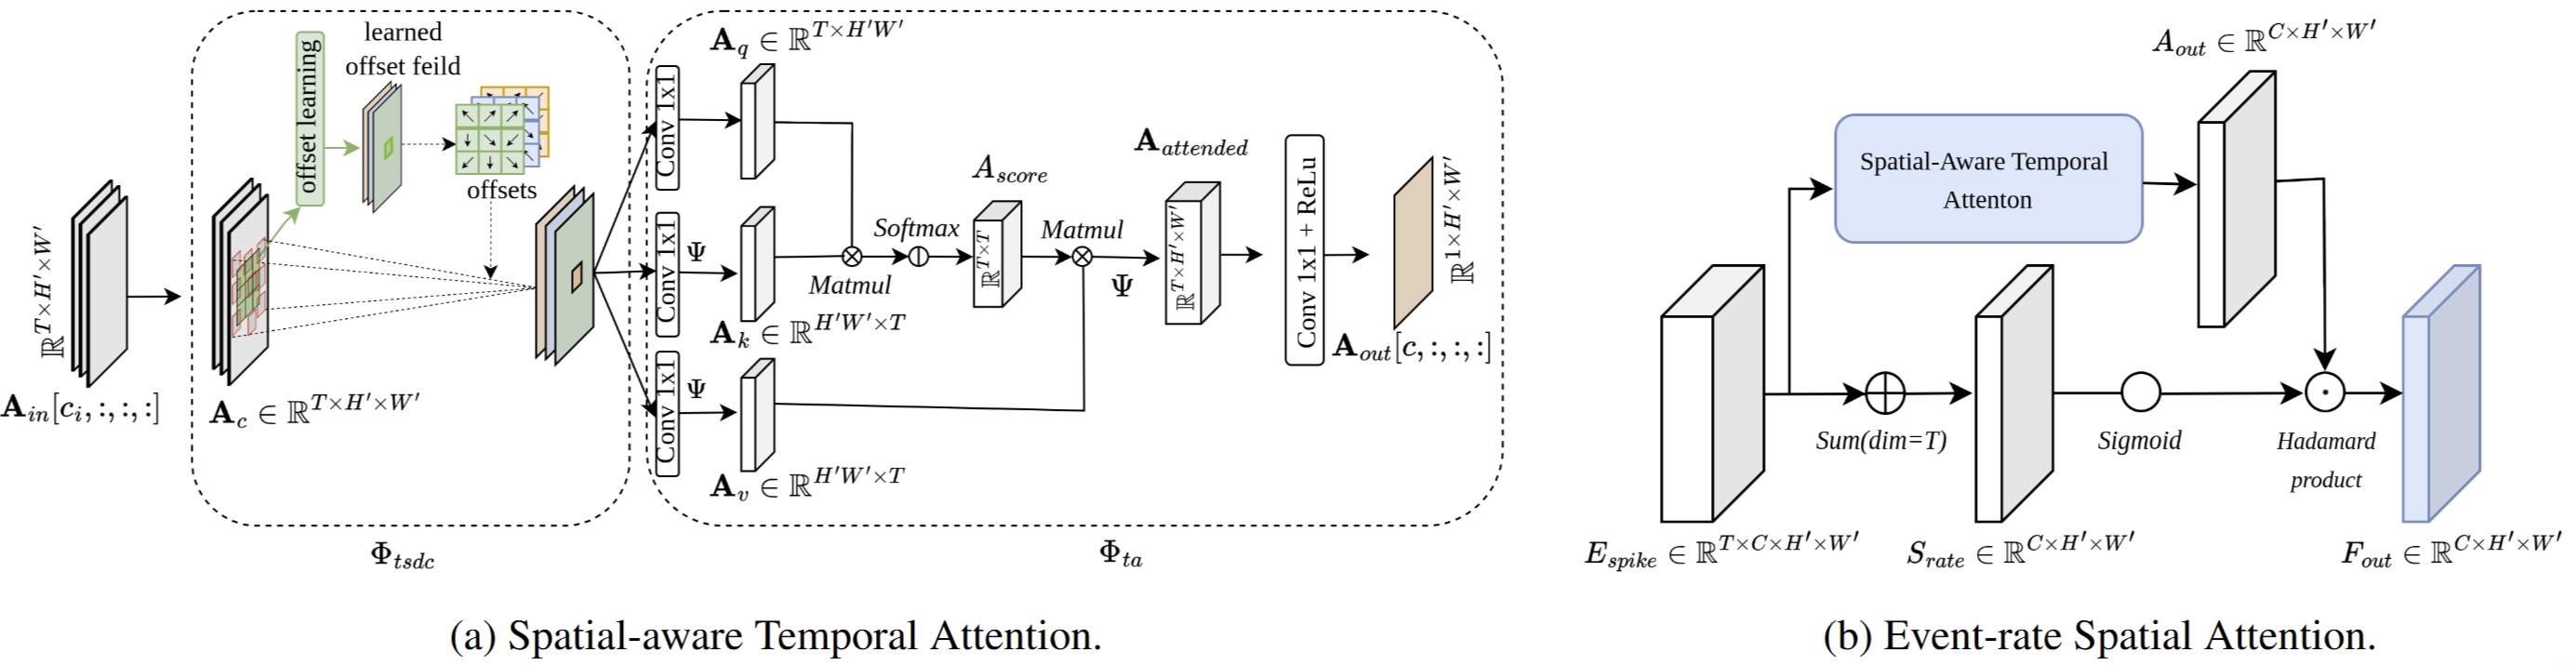
- 기존 $\mathbf{E}{spike}$ → $A{in}\in\mathbb{R}^{C\times T\times H’\times W’}$으로 reshape
Spatial-aware temporal (SAT) attention
- Time-wise separable defromable convolutions ($\Phi_{tsdc}$)
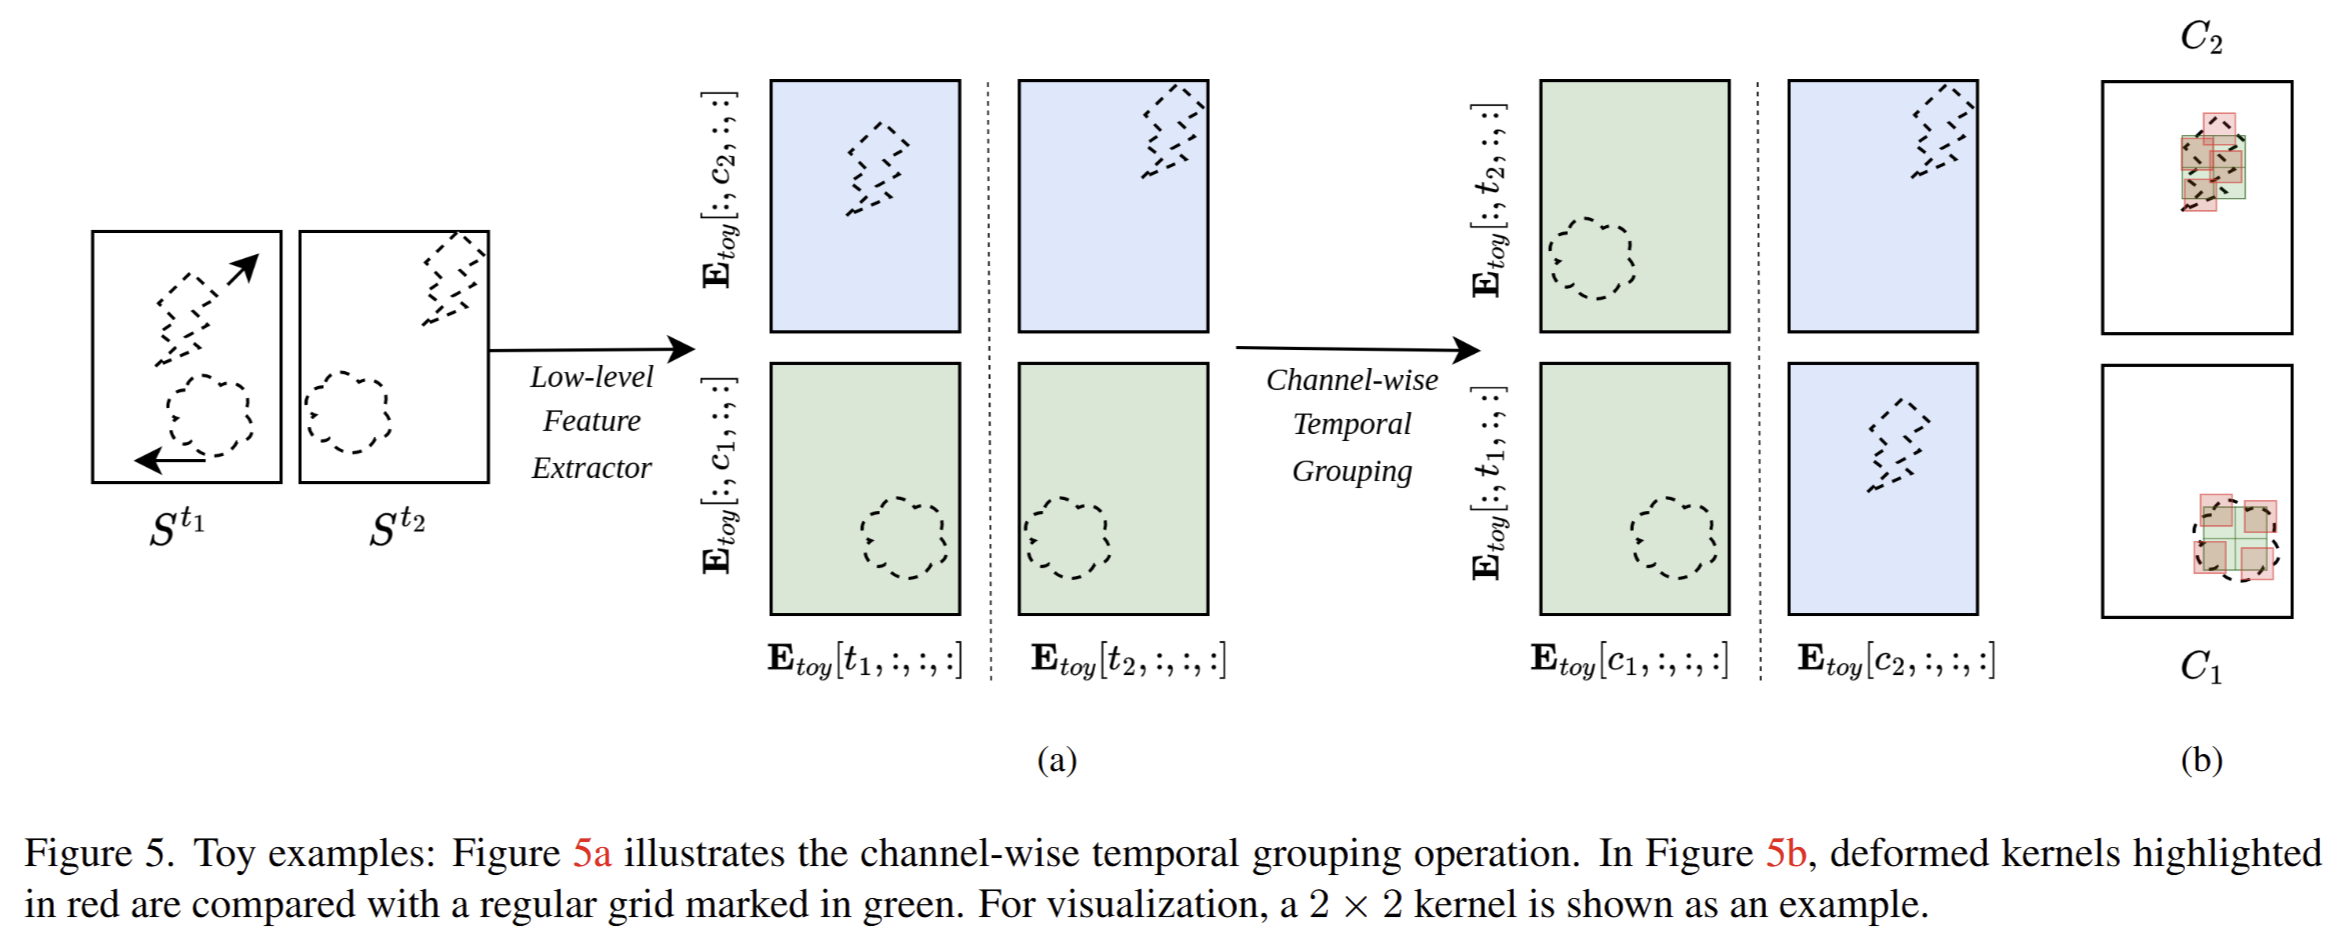
- $A_c\in\mathbb{R}^{T\times H’\times W’}$: channel-wise하게 변경
- Event camera는 object가 움직일 때 edge가 생김
- 시간이 지남에 따라 object가 이동할 때 각 시간 bin마다 event의 위치가 달라짐
- 따라서 feature에 대응하는 channel 단위로 grouping하는 방식을 사용
- deformable convolution : event와 같은 irregular representation에 강함
- 채널 별로 시간에 따라 변하는 공간 정보 추출
- 출력 : $A_{sc}$
- $A_c\in\mathbb{R}^{T\times H’\times W’}$: channel-wise하게 변경
- Temporal attention ($\Phi_{ta}$)
- $A_{sc}$를 $1\times 1$ convolution를 통과시켜 q, k, v로 나눈 후 attention 수행
- $1\times 1$ convolution + ReLU
- 어떤 시점이 중요한지를 판단
- 츨력 : $A_{out}\in\mathbb{R}^{C\times H’\times W’}$
Event-rate spatial (ERS) attention
- T 차원으로 summation : 전체 시간 동안의 spatial spike 계산
- Sigmoid : 공간적으로 중요한 영역 강조
- SAT 출력 $A_{out}$과 hadamard product
- 출력 : $F_{out}\in\mathbb{R}^{C\times H’\times W’}$
ANN block
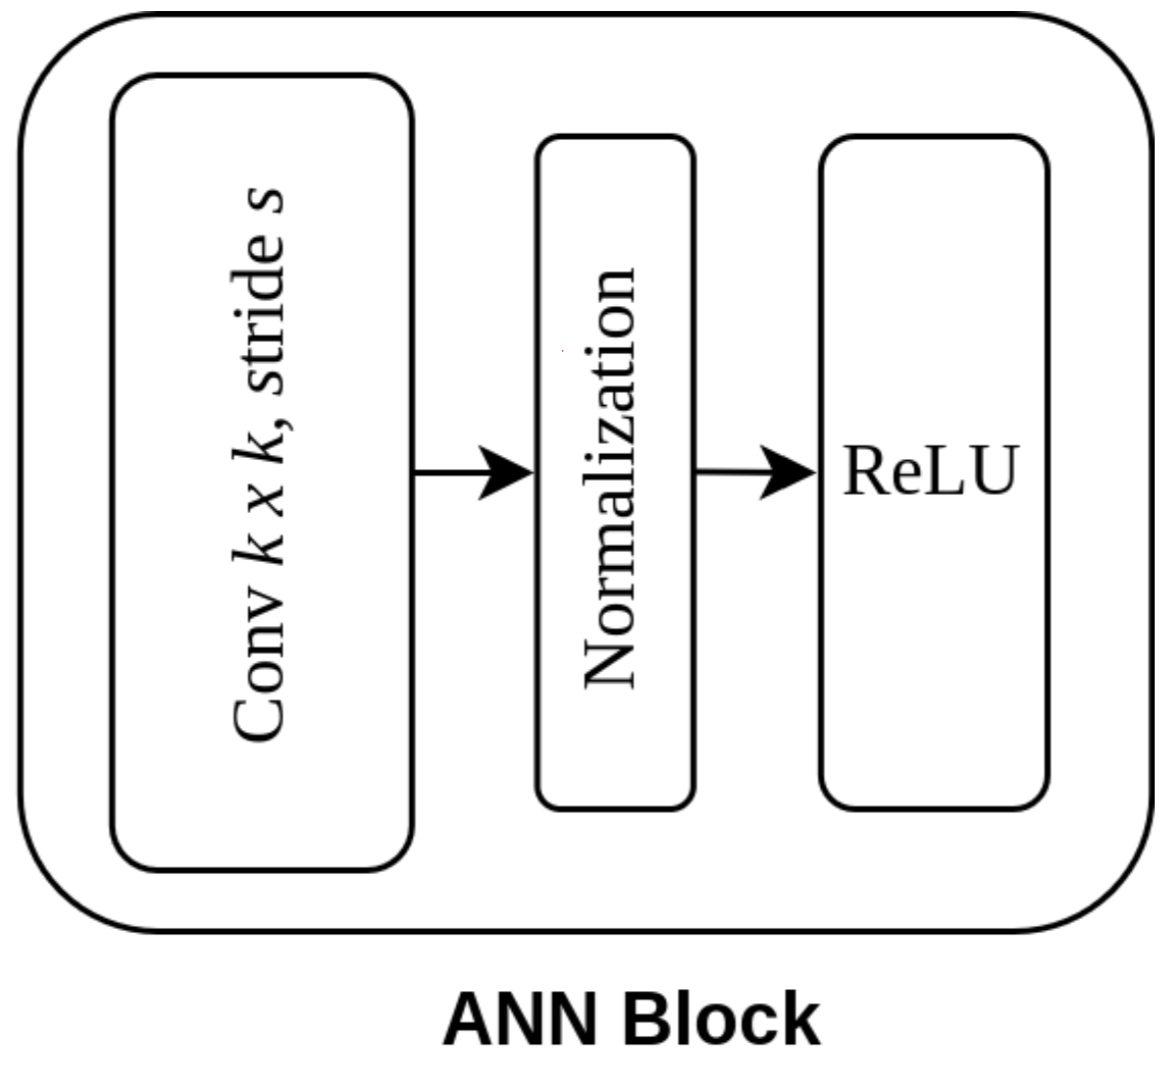
- convolution, normalization, ReLU로 구성
- detail한 high-level spatial feature 추출
Results
- Dataset : Gen1 Automotive Detection, Gen4 Automotive Detection
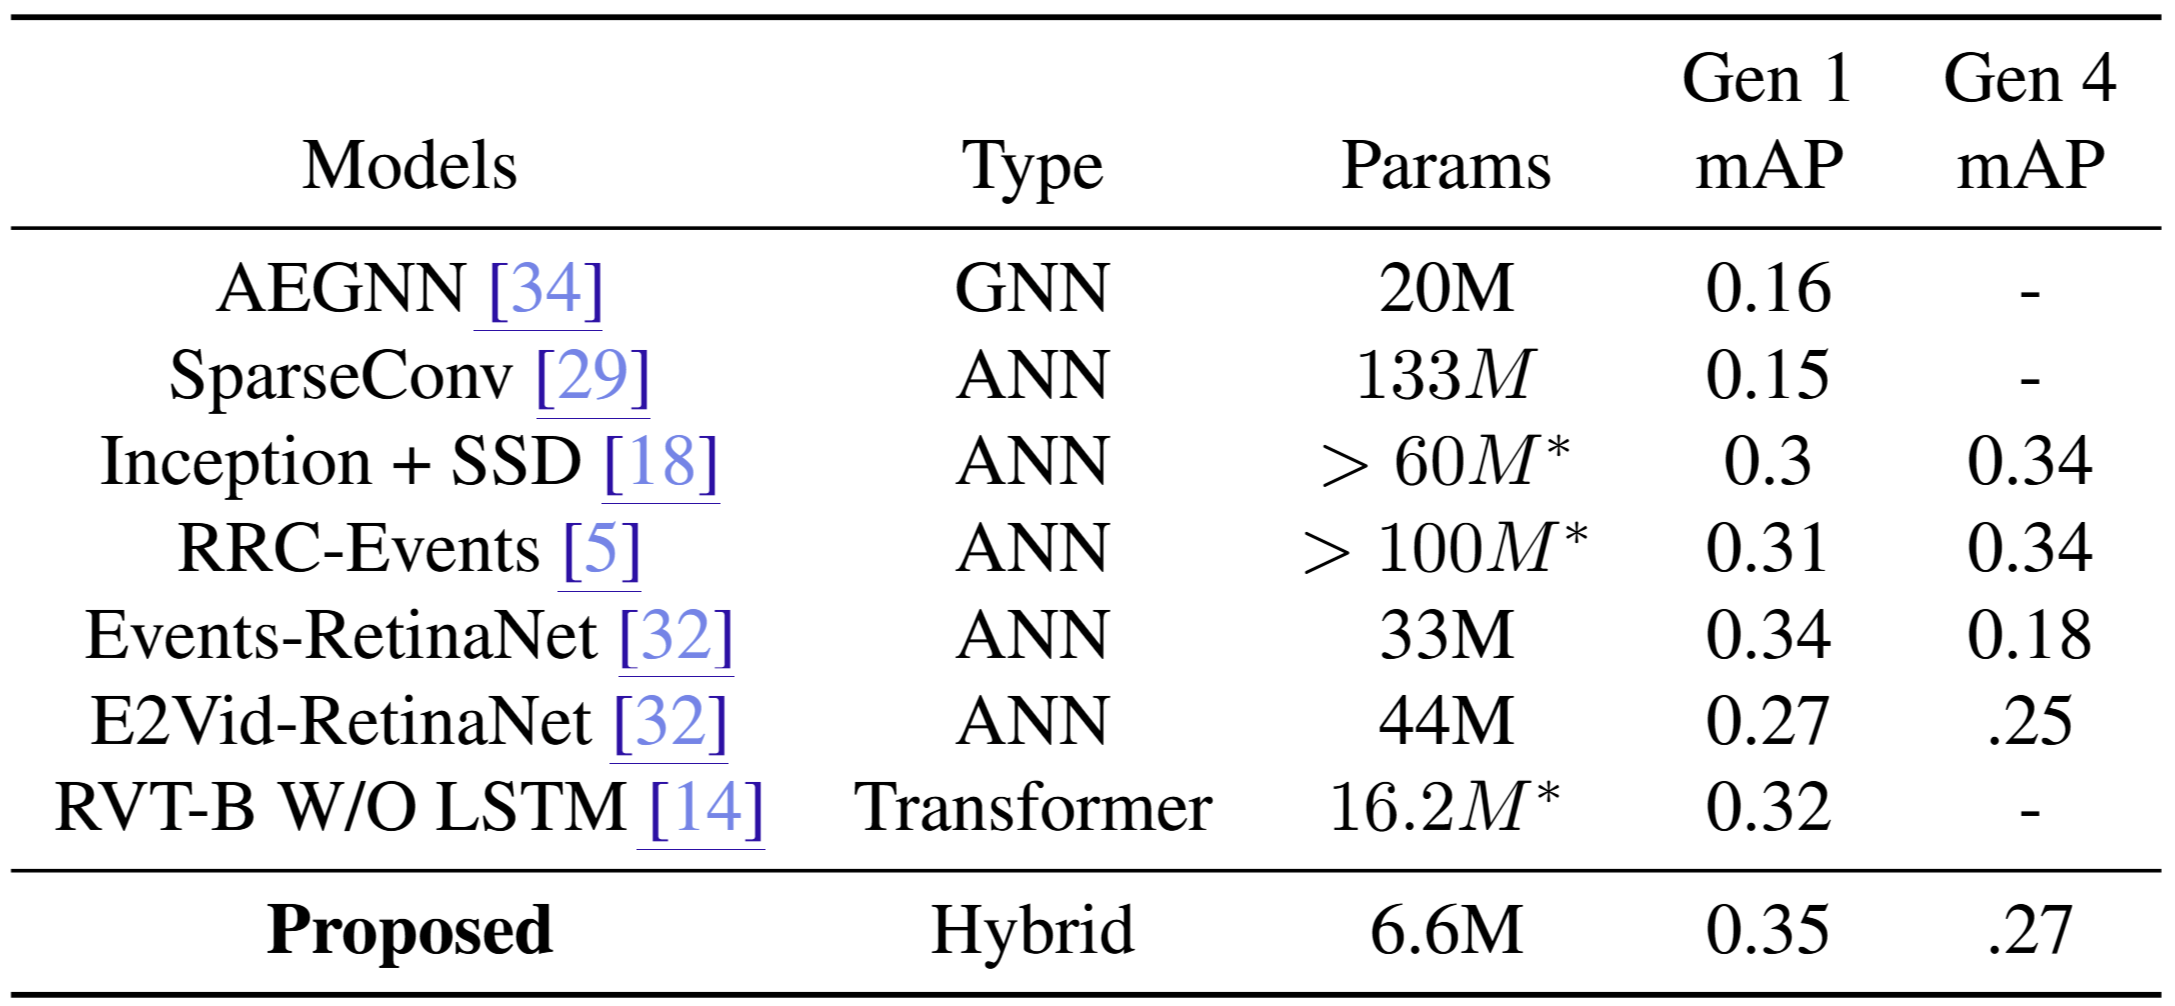
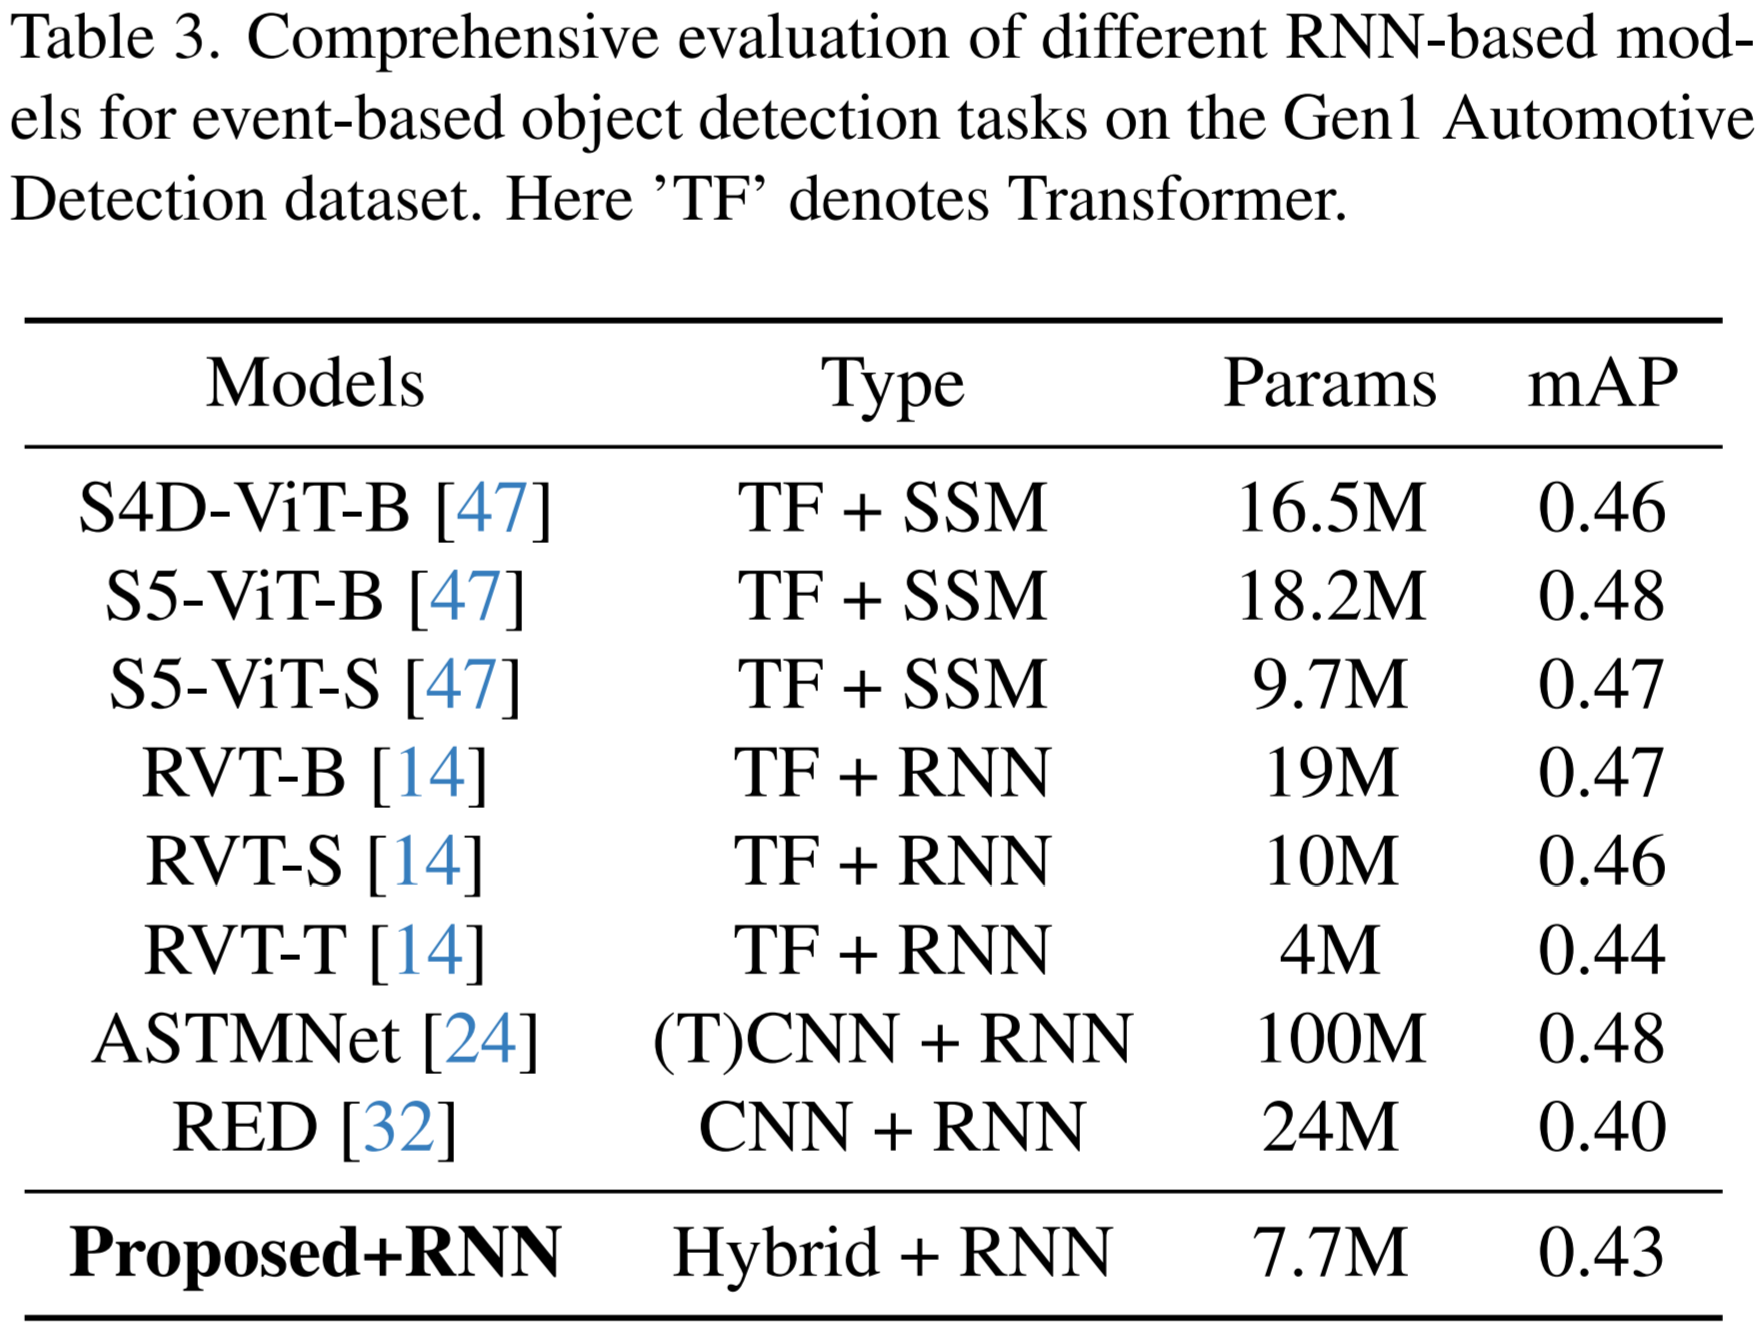
- WDConvLSTM은 자세히 나와있지 않음